KEENON Robotics
KEENON Robotics XMAN-F1
Industrie et servicesRobots humanoïdes
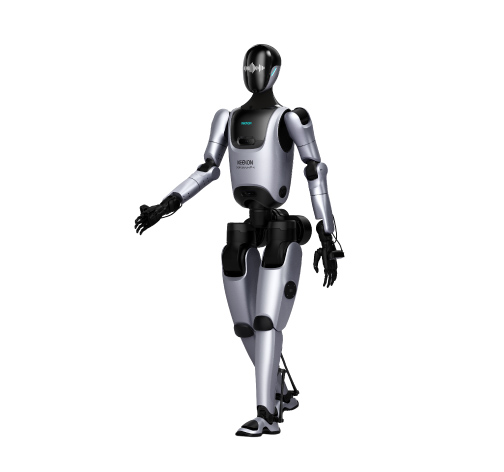
Bipedal humanoid platform for service tasks, combining articulated hands, multimodal perception and a facial display. KEENON describes coordination with other robot types and VR dual-arm teleoperation.
Prix sur demande
Parlons de votre projetPrésentation
Usages adaptés
- Commercial service development
- Bipedal manipulation research
Caractéristiques principales
| Hauteur | 175 cm |
|---|---|
| Poids | 68 kg |
| Whole-body degrees of freedom | 43 |
| Arms | 7 degrés de liberté par bras |
| Pattes | 6 DoF per leg |
| Waist | 3 DoF |
| Sensing | 3D LiDAR, 4 depth cameras, 4 wide-angle cameras |
| Calcul IA | 275 TOPS; 64 GB VRAM |
Capacités et points forts
- 43 stated whole-body degrees of freedom
- 3D LiDAR and eight cameras
Limites à connaître
- Battery endurance and payload are not disclosed in the reviewed sheet
- Autonomous task capability depends on integration and deployment
Documentation et sources
Informations vérifiées le 2026-10-27. Les chiffres dépendent de la configuration et des conditions d’essai.