KEENON Robotics
对比你关心的用途、优势和取舍。
正在加载对比…
添加另一个机器人来比较. 最多可以比较四个
先用药. 接下来是规格 源头总是可以找到的。
刷或滚动桌子. 型号和标准应始终注意。
| 比较 | KEENON RoboticsXMAN-F1 |
|---|---|
| 决定至关重要 | |
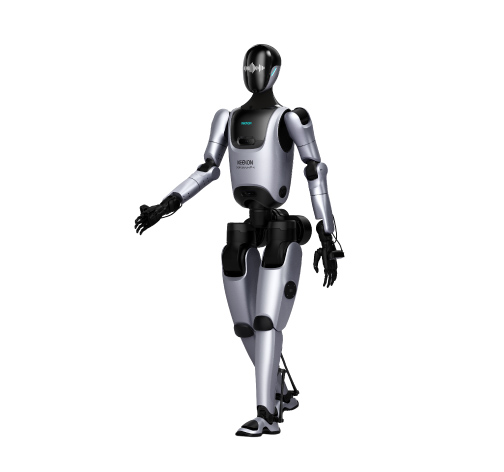
| 它会做什么 | Bipedal humanoid platform for service tasks, combining articulated hands, multimodal perception and a facial display. KEENON describes coordination with other robot types and VR dual-arm teleoperation. |
| 不错 |
|
| 主要优势 |
|
| 需要权衡的因素 |
|
| 能力与性能 | |
| Whole-body degrees of freedom | 43 |
| Arms | 7 DoF per arm |
| Legs | 6 DoF per leg |
| Waist | 3 DoF |
| Sensing | 3D LiDAR, 4 depth cameras, 4 wide-angle cameras |
| AI computing | 275 TOPS; 64 GB VRAM |
| 大小和部署 | |
| 高度 | 175 cm |
| 重量 | 68 kg |
| 预算, 供货情况 源代码( R) | |
| 准确版本 | XMAN-F1 |
| 供应商价格及币种 | 联系制造商询价 检查价格 2026年10月27日 · 价格来源 |
| 供货与支持 | Manufacturer-listed. Commercial availability, configuration and regional delivery unconfirmed. |
| 检查目录 | 2026年10月27日 |
| 产品来源 | |
| KEENON RoboticsXMAN-F1 |
|---|
决定至关重要 |
| 它会做什么 |
Bipedal humanoid platform for service tasks, combining articulated hands, multimodal perception and a facial display. KEENON describes coordination with other robot types and VR dual-arm teleoperation. |
| 不错 |
|
| 主要优势 |
|
| 需要权衡的因素 |
|
能力与性能 |
| Whole-body degrees of freedom |
43 |
| Arms |
7 DoF per arm |
| Legs |
6 DoF per leg |
| Waist |
3 DoF |
| Sensing |
3D LiDAR, 4 depth cameras, 4 wide-angle cameras |
| AI computing |
275 TOPS; 64 GB VRAM |
大小和部署 |
| 高度 |
175 cm |
| 重量 |
68 kg |
预算, 供货情况 源代码( R) |
| 准确版本 |
XMAN-F1 |
| 供应商价格及币种 |
联系制造商询价 检查价格 2026年10月27日 · 价格来源 |
| 供货与支持 |
Manufacturer-listed. Commercial availability, configuration and regional delivery unconfirmed. |
| 检查目录 |
| 2026年10月27日 |
| 产品来源 |
制造商 规格可以使用不同的条件或配置. 缺失的数据从未作为零处理. 测试分数来自被命名的独立出版社.
价格如下所示: USD. 税收、附件、交货和安装取决于引用的配置。