选择准确的版本
R1-7aR1
概述
适用场景
- Laboratory manipulation experiments
- 机器人教育
主要规格
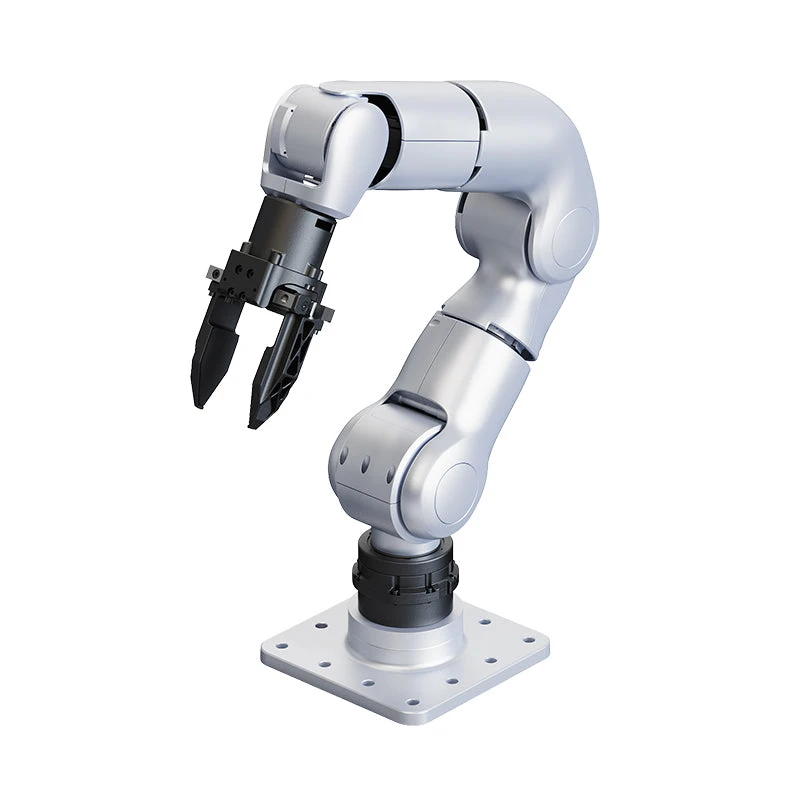
| 关节 | 7 |
|---|---|
| 有效载荷 | 2 kg |
| 工作半径 | 650 mm 手柔软 |
能力与优势
- Seven-axis movement
- Force feedback and collision detection
重要局限
- Open-source control programs are being released progressively.
- Unitree warns that low joint reduction can cause positional error or oscillation without control optimisation.