What to consider before choosing
Typical environments include:
- Production cells
- Part transfer
Assembly automation starts with the part presentation and required placement quality. Choose tooling, sensing and fixtures around real tolerances before comparing arm specifications.
Typical environments include:
Inclusion means the robot is mapped to this use case from available product information. It is not a guarantee that the product fits every site.
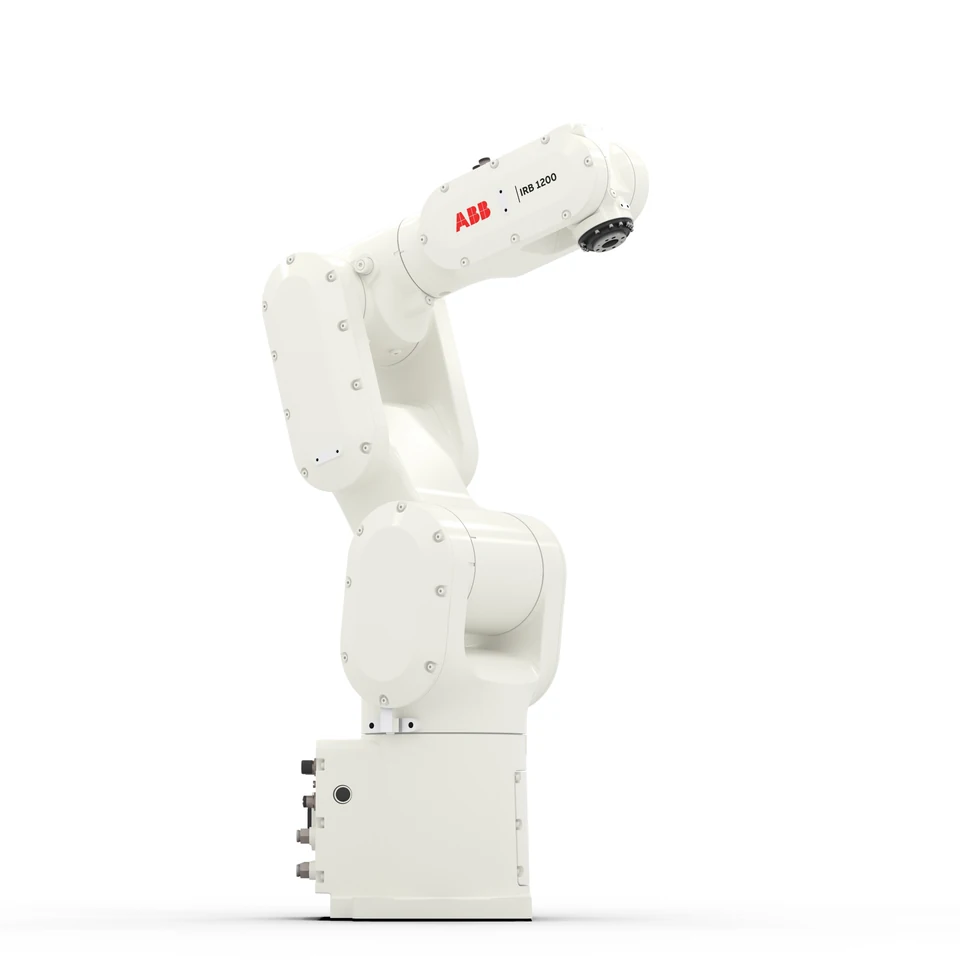
Small-part assembly
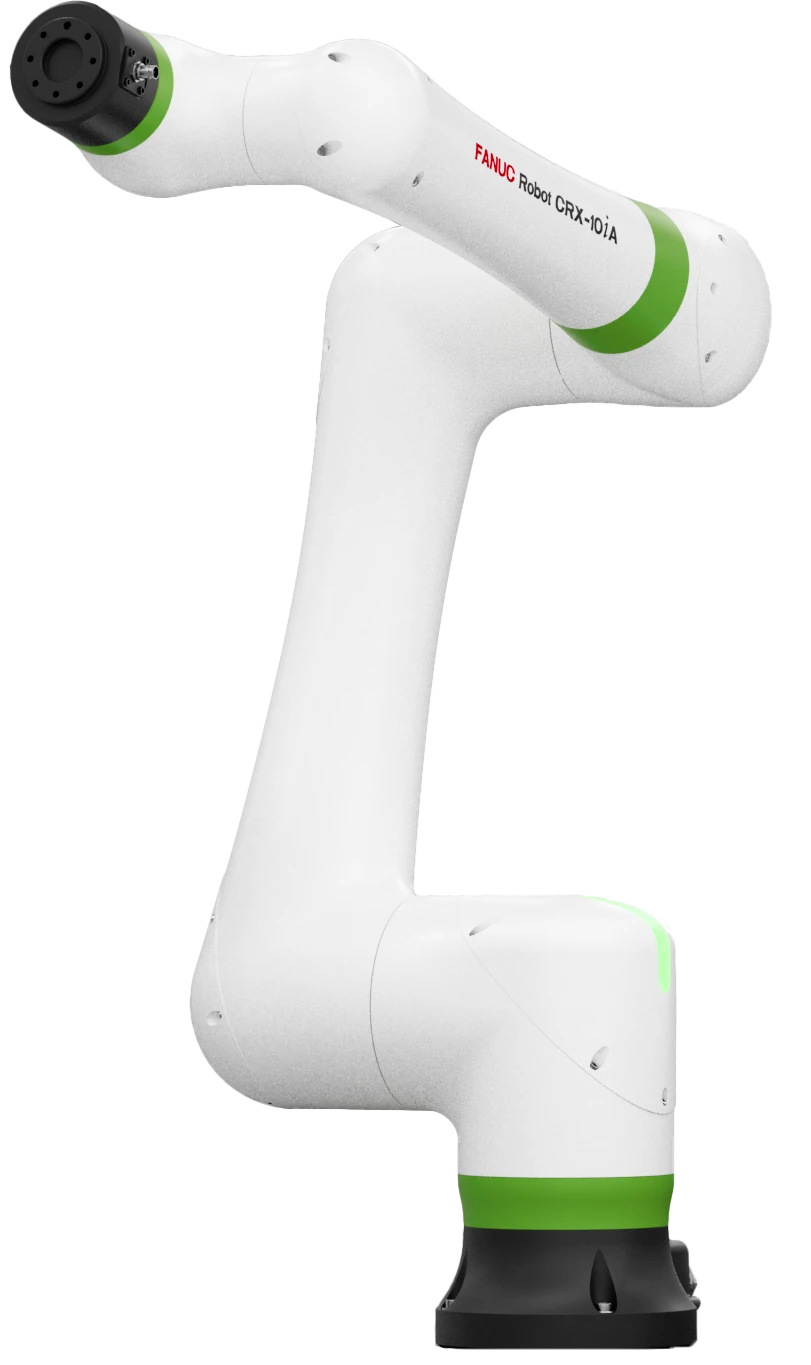
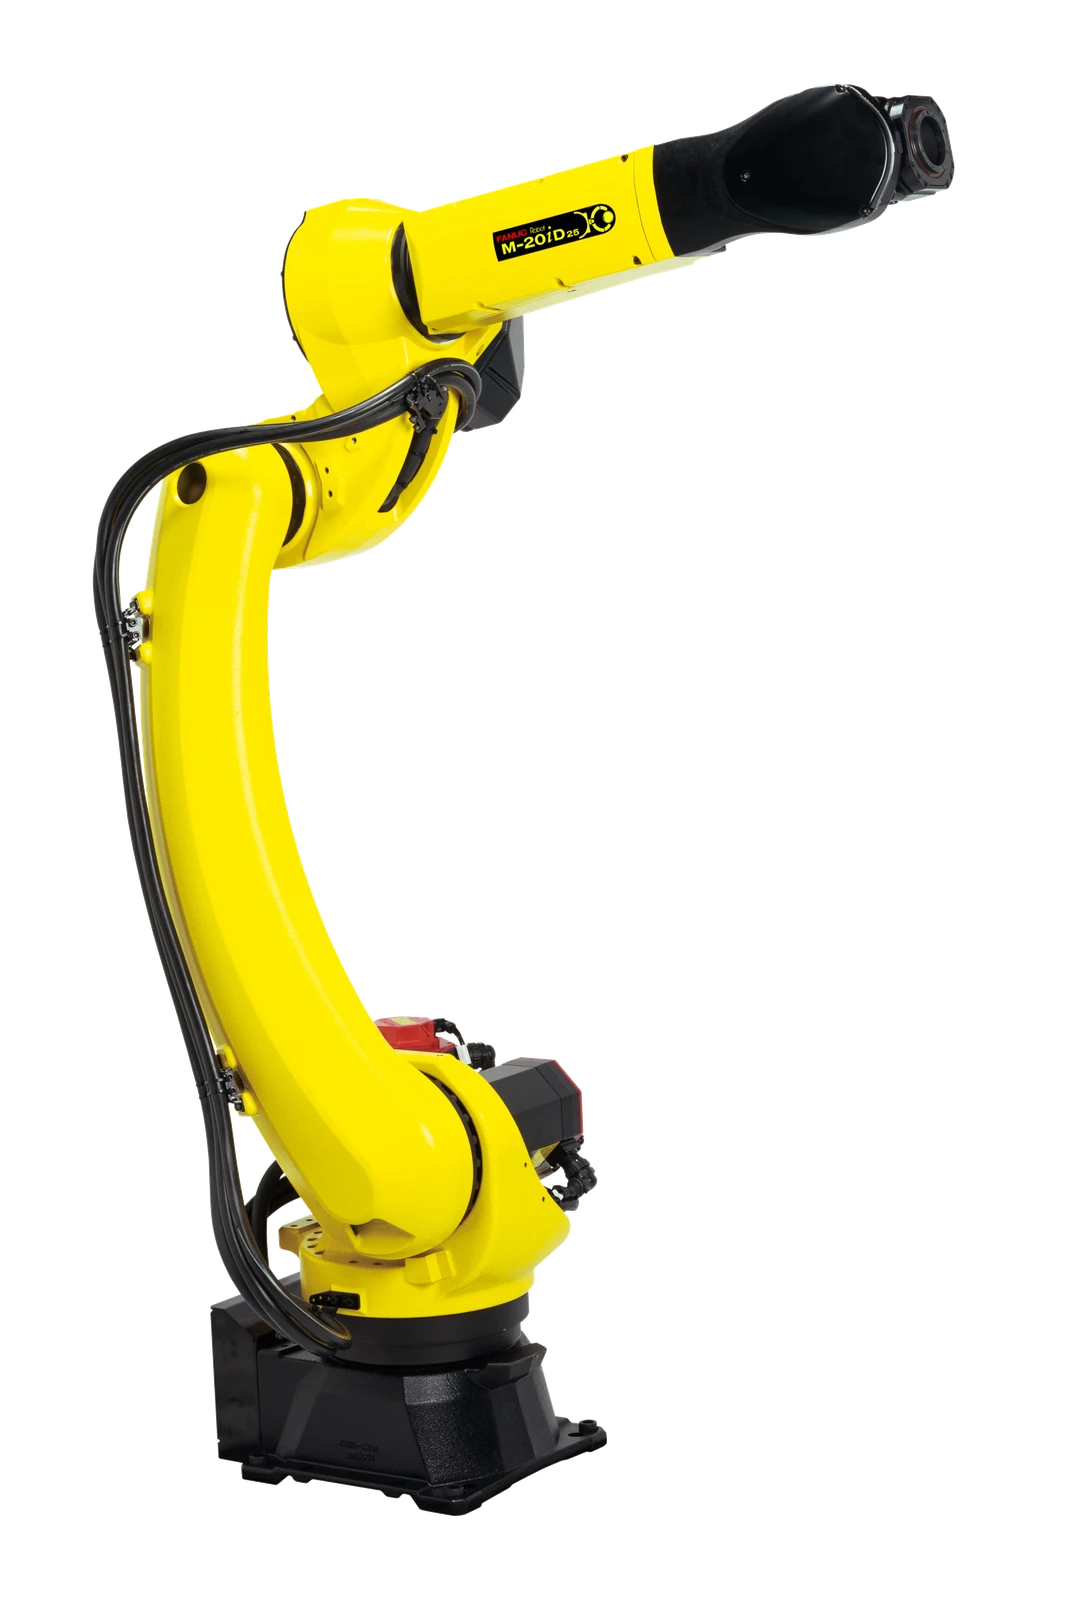
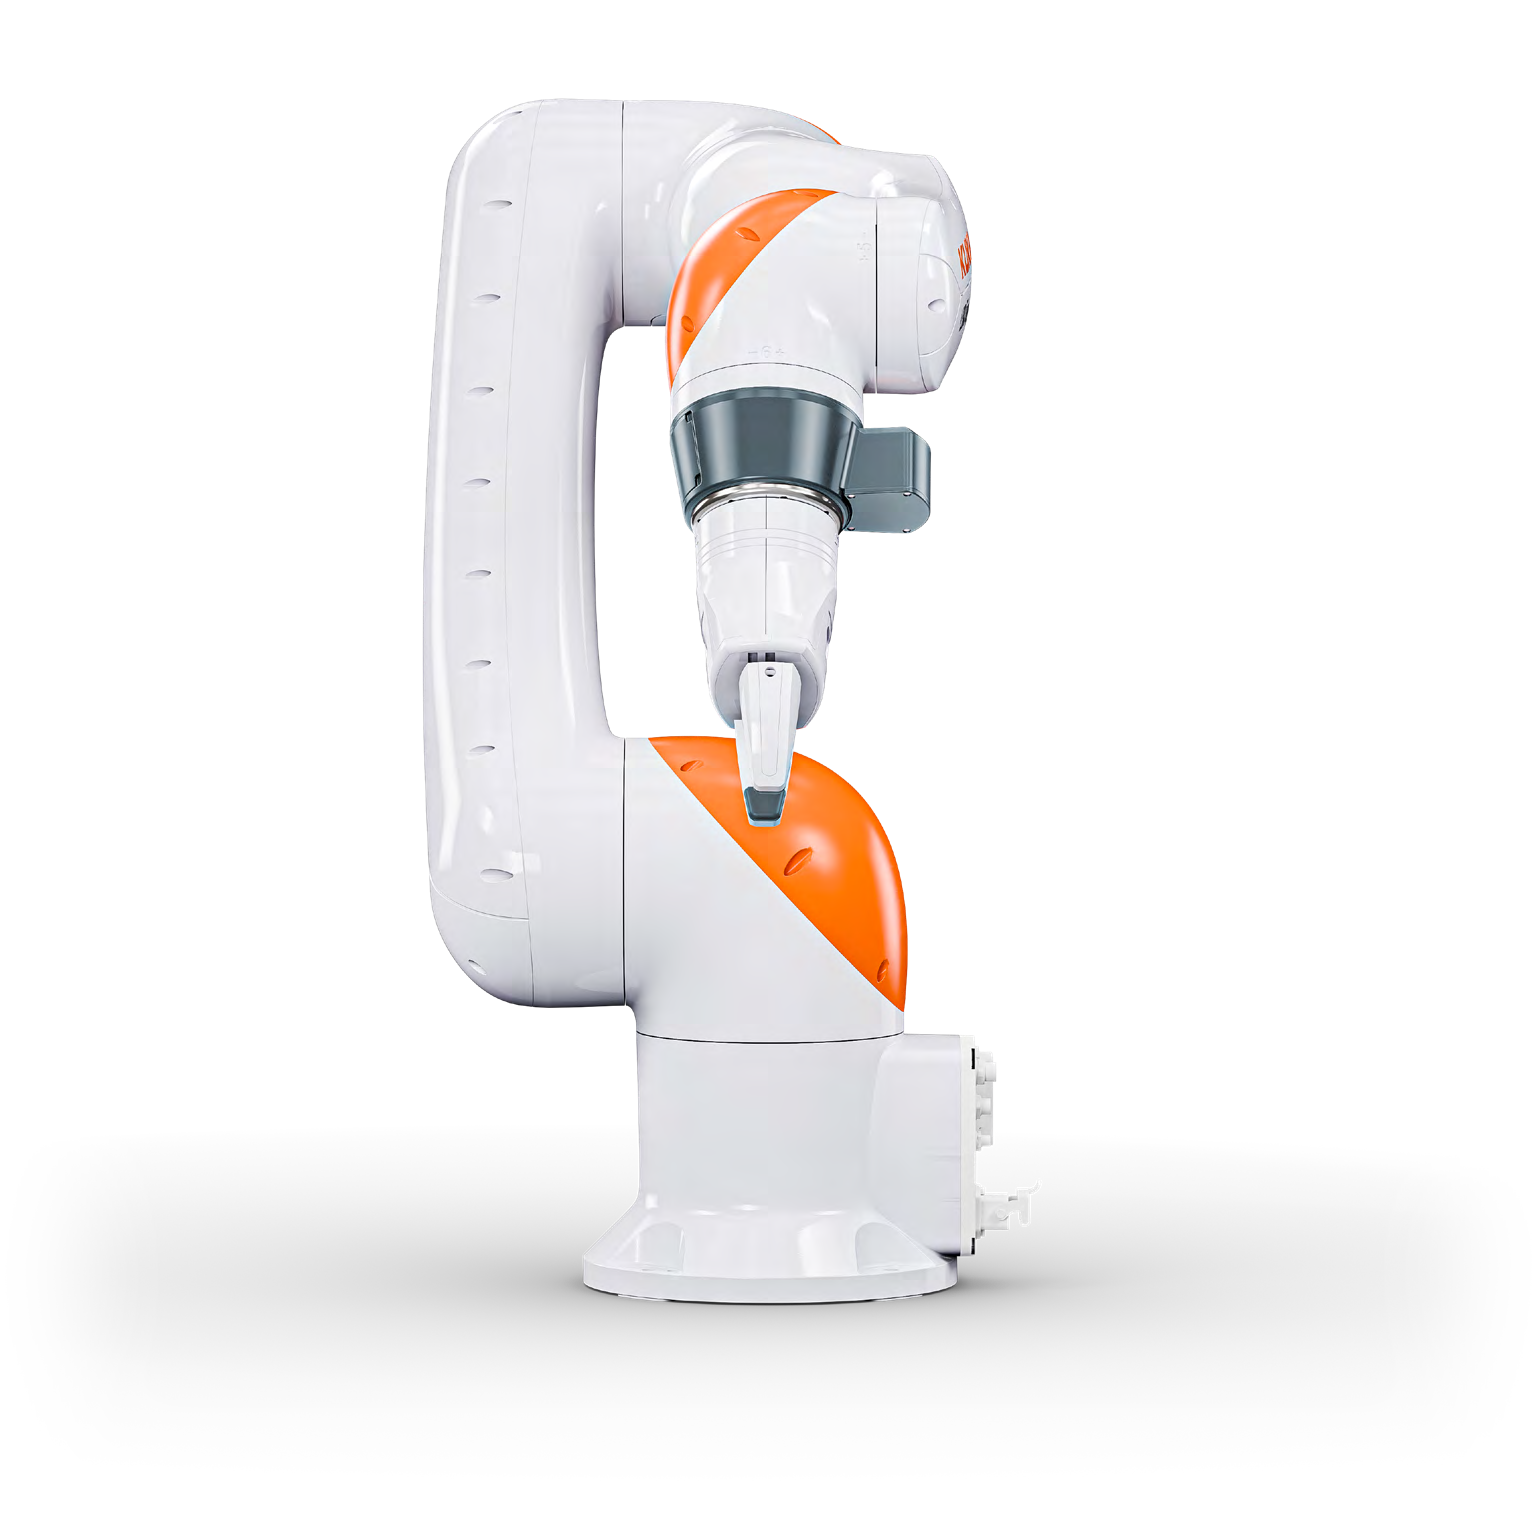
Handling cells
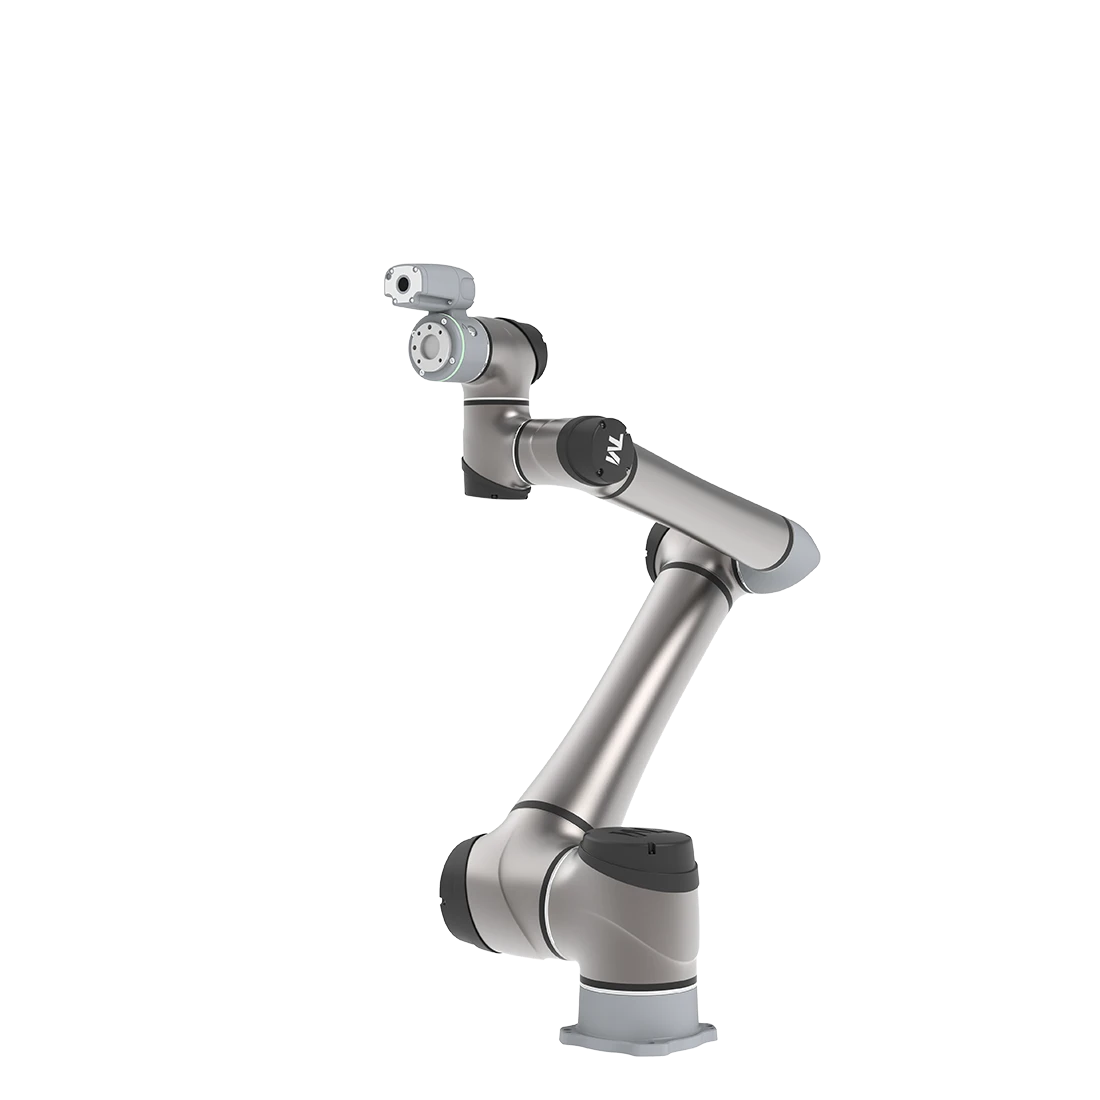
Vision-guided handling
| Robot | Price / status | Published detail | Check before choosing |
|---|---|---|---|
| ABB IRB 1200-7/0.7 Gen2 | Contact manufacturer | Arm payload: 7 kg | Tooling and cell integration require separate engineering |
| FANUC CRX-10iA | Contact manufacturer | Arm payload: 10 kg | Application risk assessment still required |
| FANUC M-20iD/25 | Contact manufacturer | Arm payload: 25 kg | Gripper mass is part of the load calculation |
| KUKA LBR iisy 11 R1300 | Contact manufacturer | Arm payload: 11 kg | Application safety assessment remains necessary |
| Techman TM12S | Contact manufacturer | Arm payload: 12 kg | Validate vision performance on the actual parts |
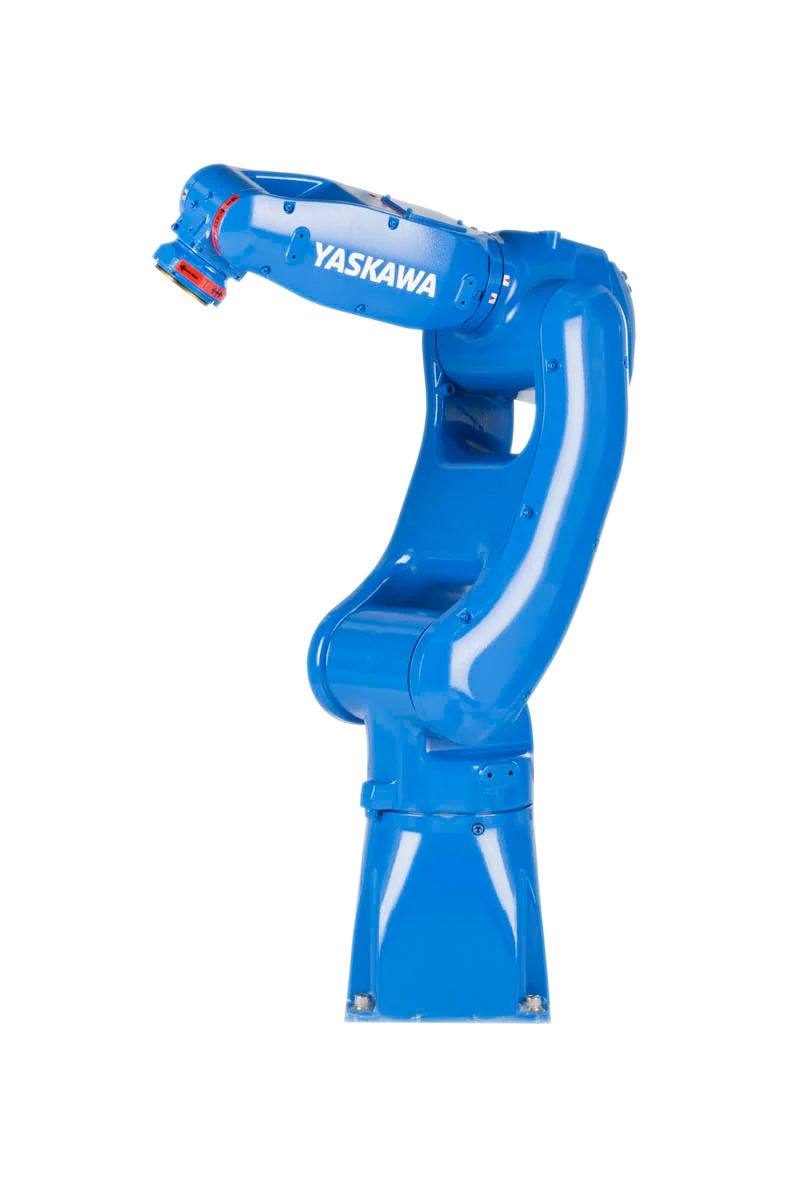
| Yaskawa MOTOMAN GP8 | Contact manufacturer | Arm payload: 8 kg | Confirm controller and programming package in the quote |