概述
适用场景
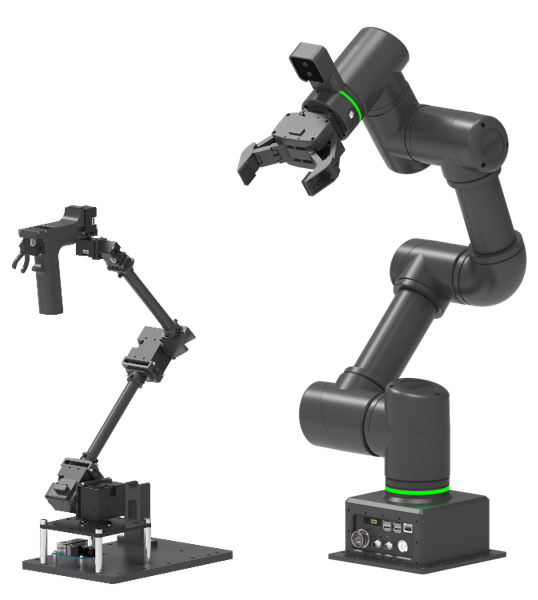
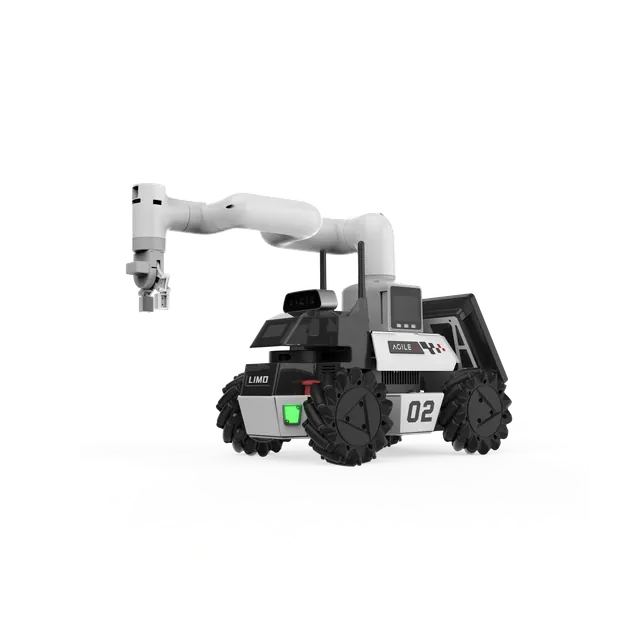
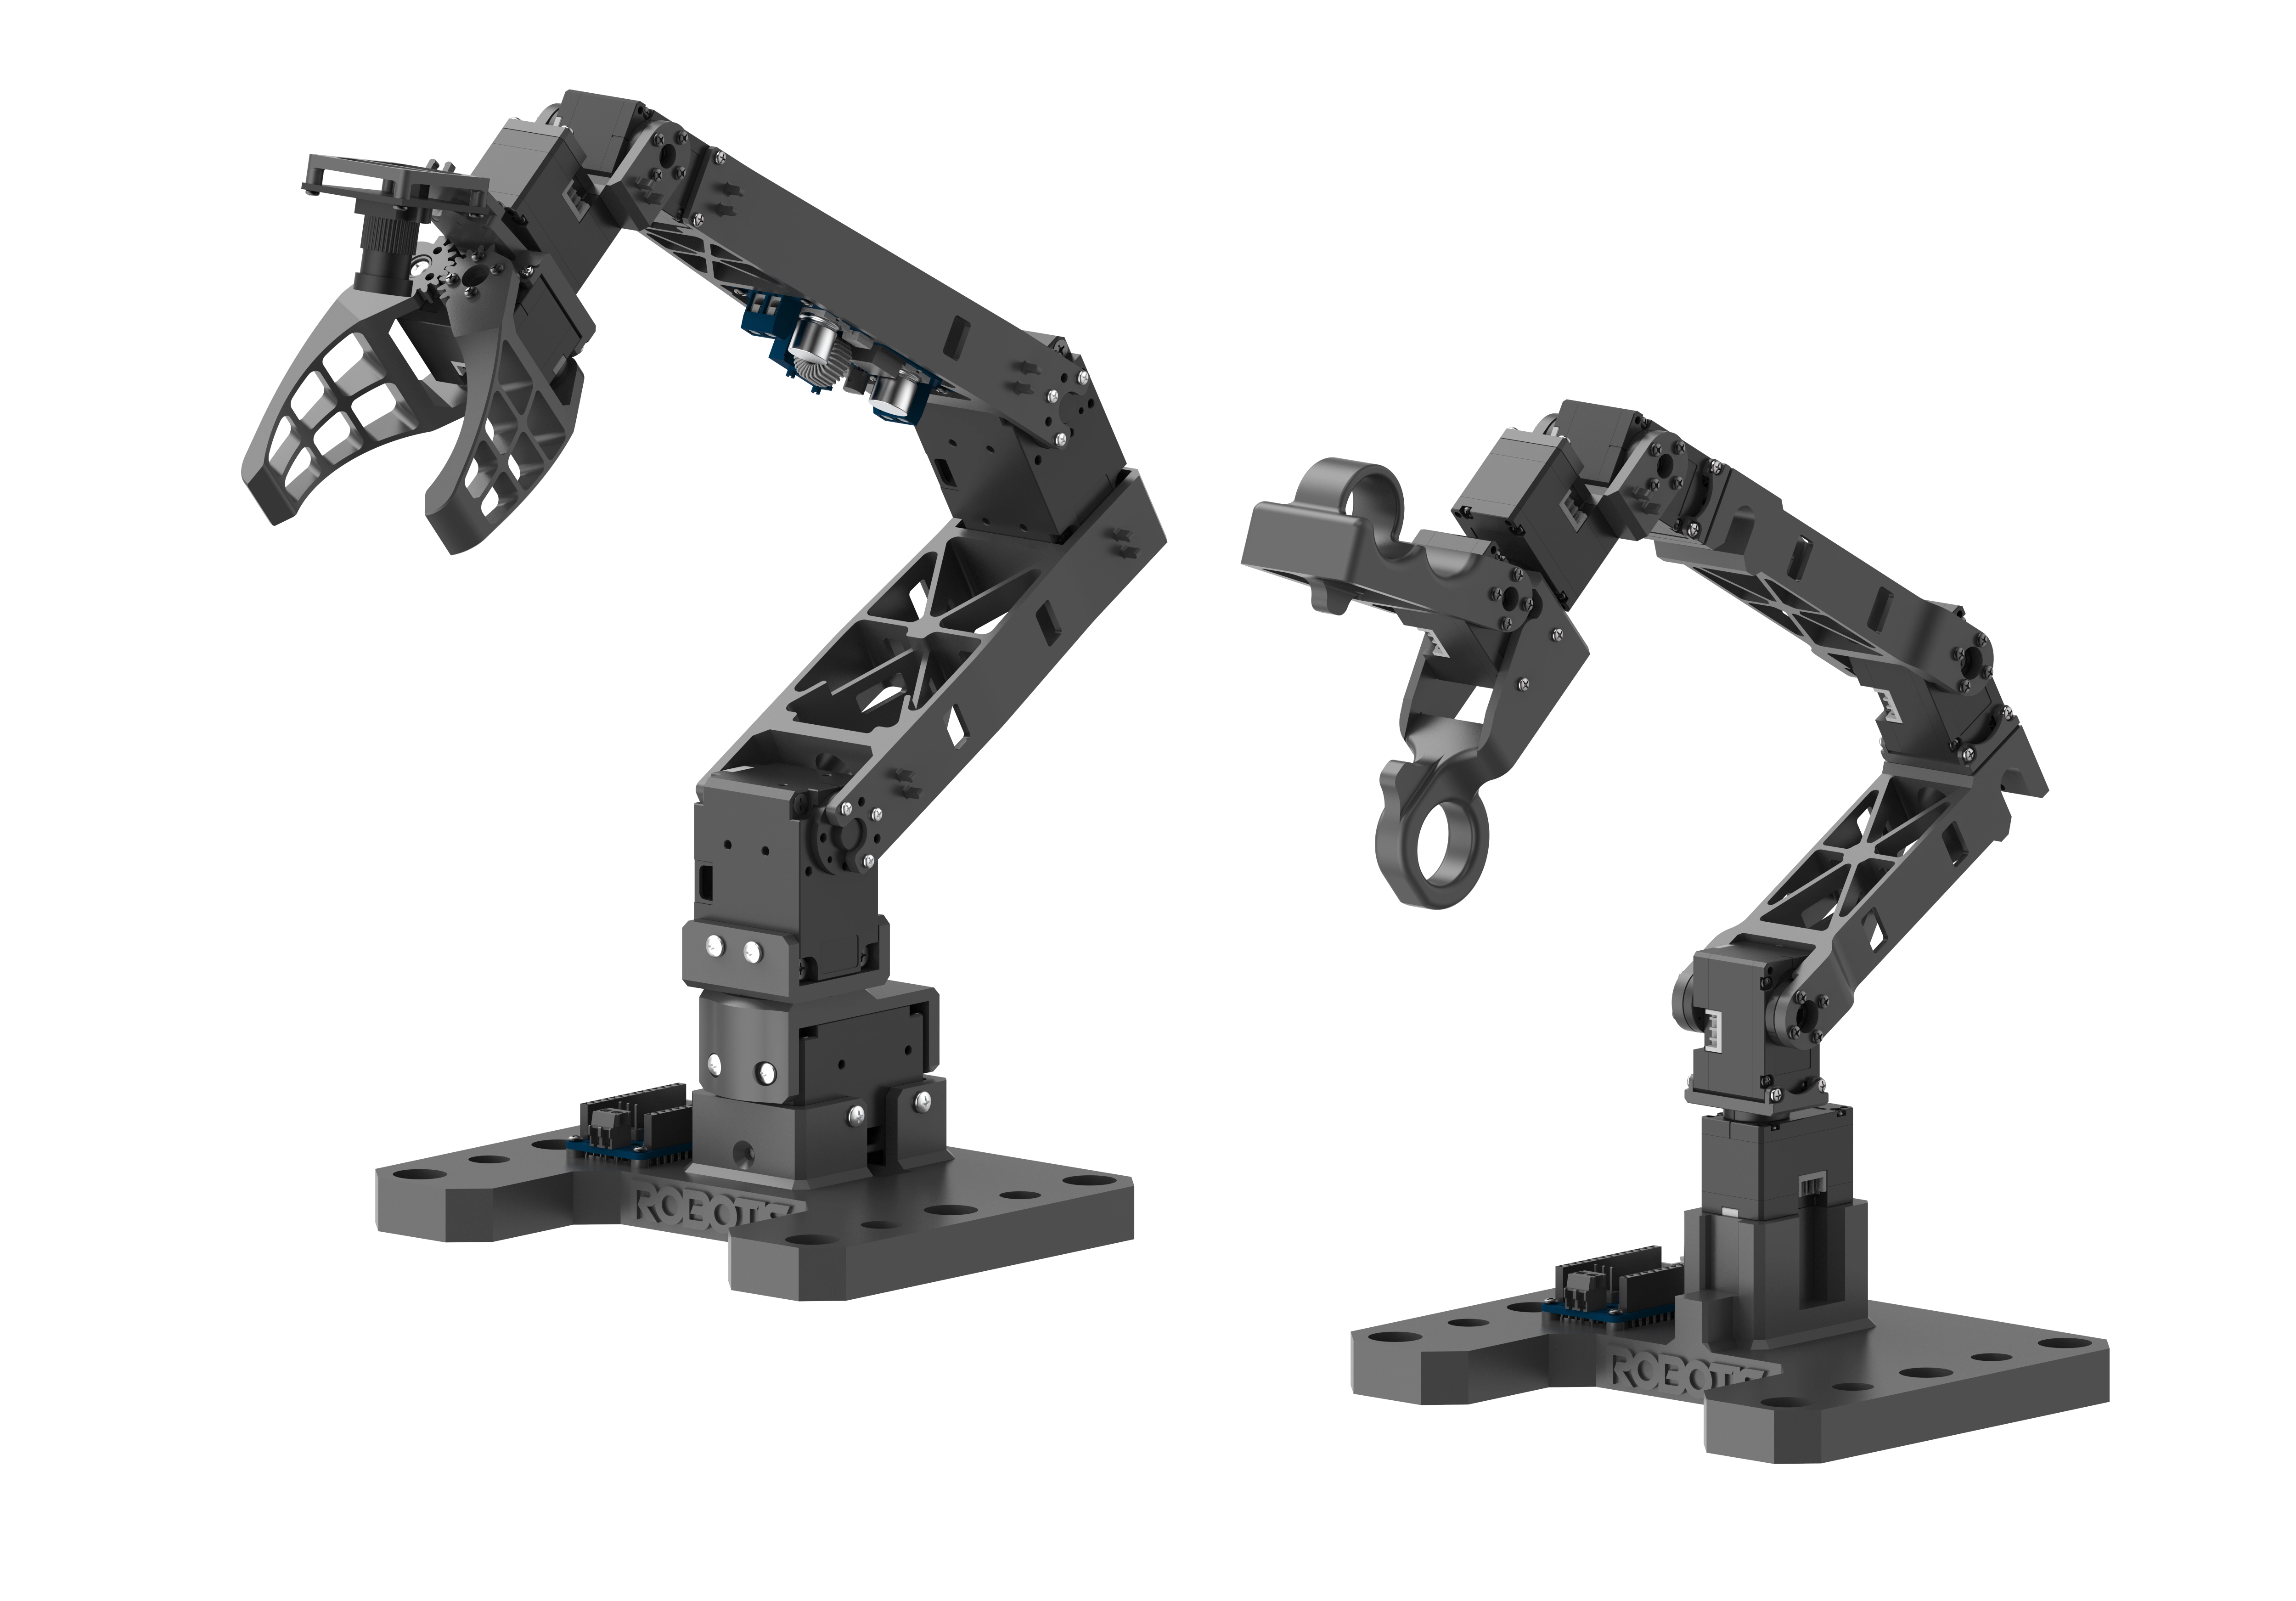
- Laboratory manipulation and imitation learning
主要规格
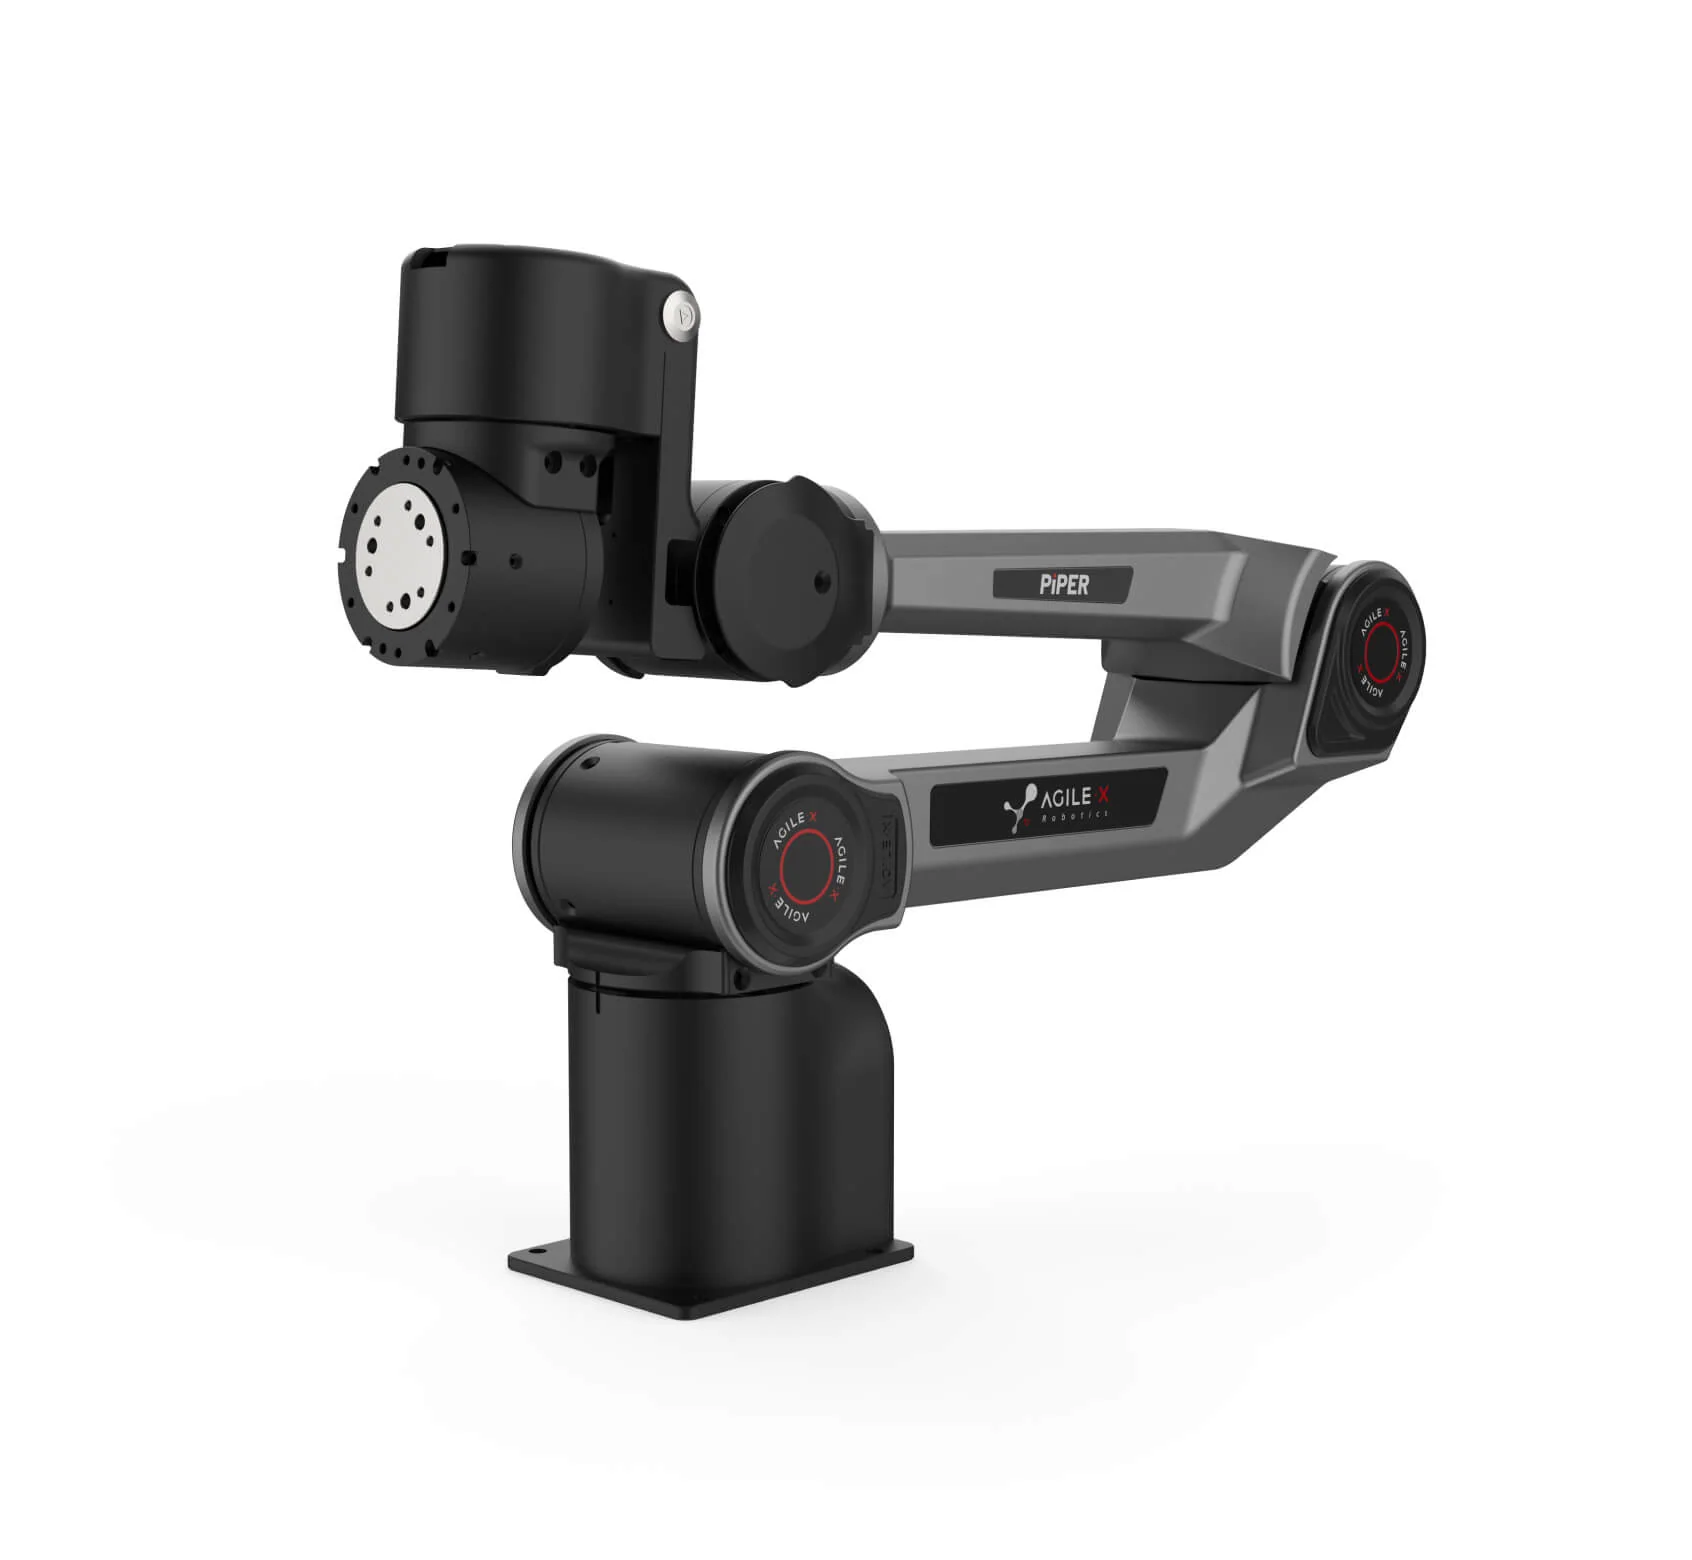
| 自由度 | 6 |
|---|---|
| 有效载荷 | 1.5 kg |
| 工作半径 | 669 mm |
| 重量 | 4.5 kg |
| 可重复性 | ±0.1 mm |
| Supply | DC 24 V |
能力与优势
- Open software interfaces and flexible wrist orientation
重要局限
- End effectors and cameras depend on configuration; automatic obstacle sensing is not included.