Industry & service
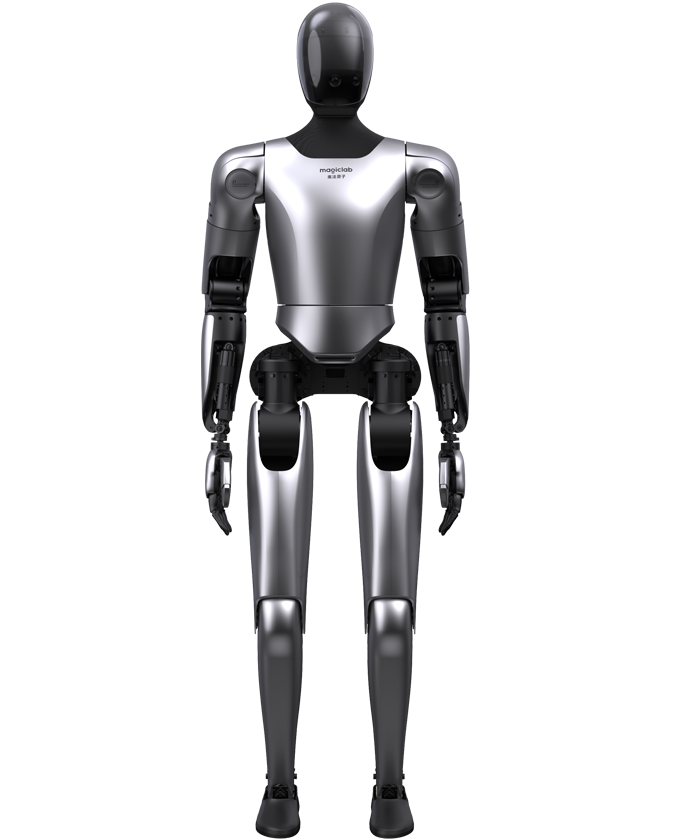
MagicLabMagicBot Gen1
Industrial humanoid development
- Weight
- ≈ 70 kg
Price on request
Workplace deployment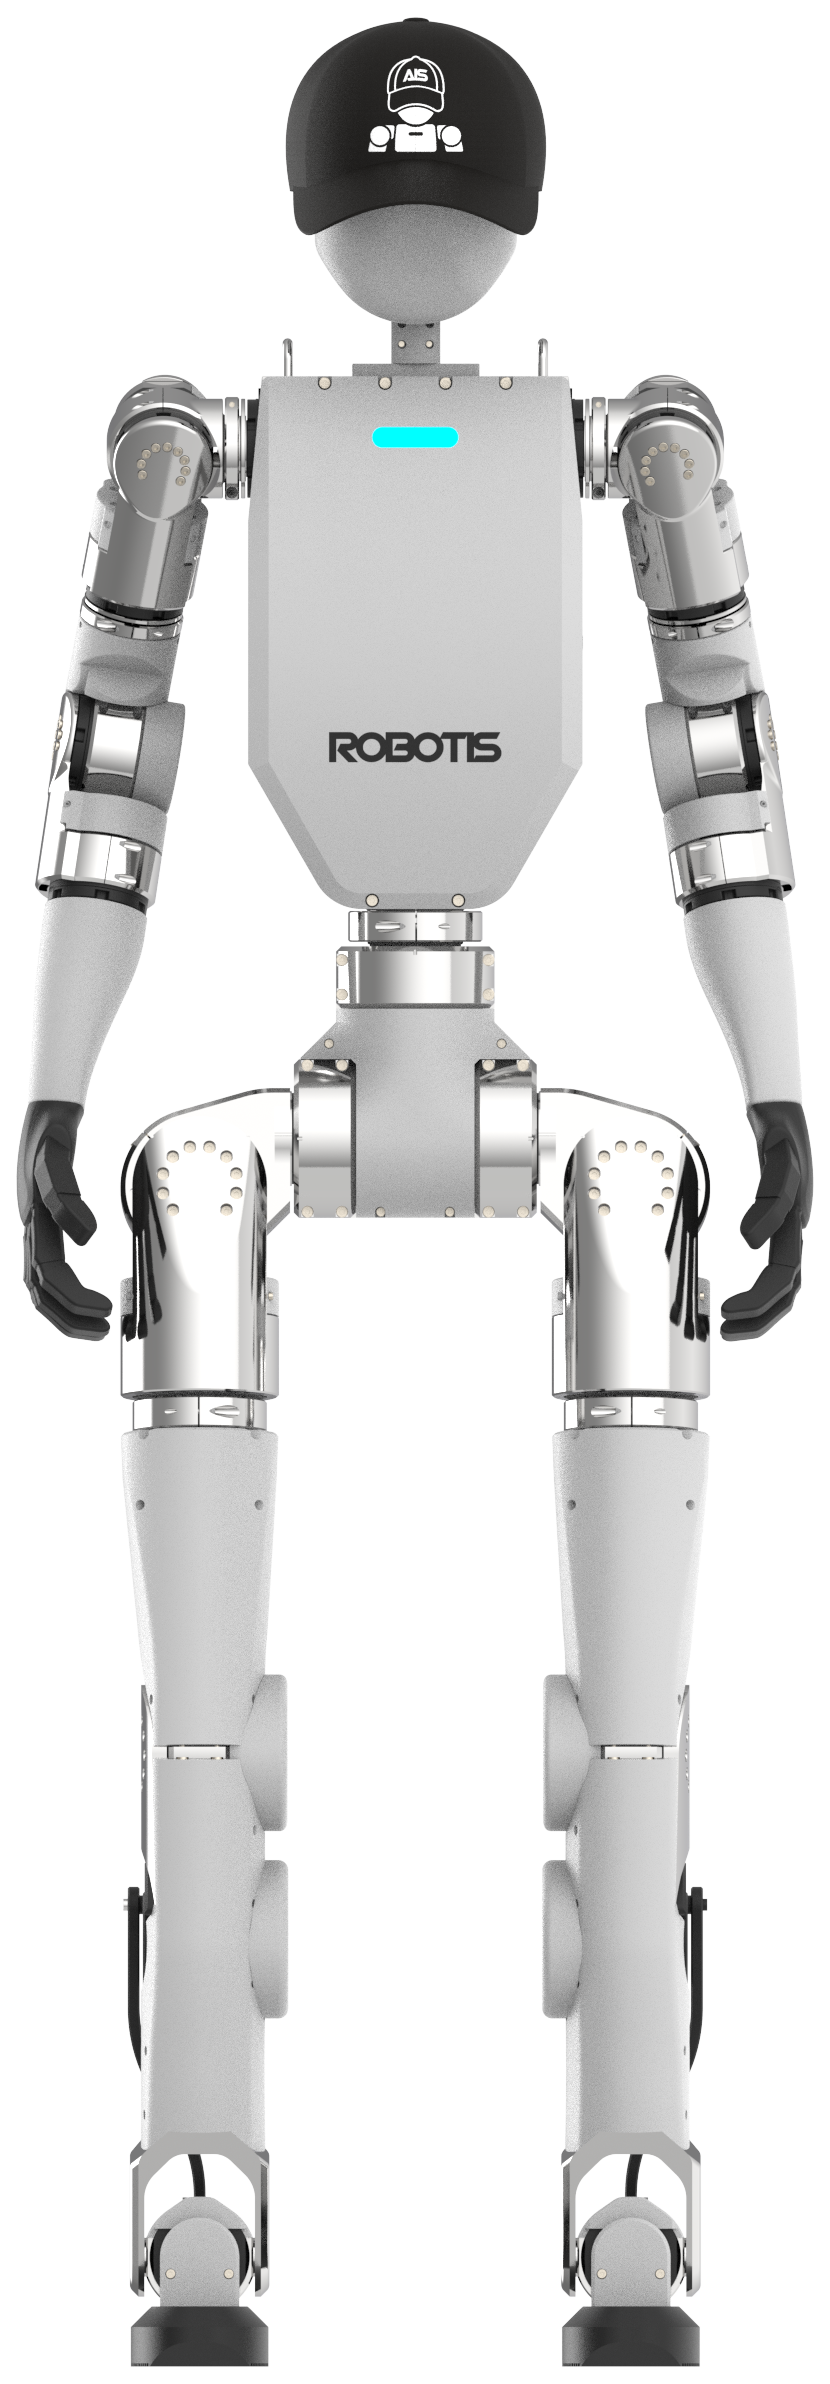
A humanoid development platform for locomotion, motion control and learning policies on physical hardware. The current K1 documentation describes a twenty-three-axis body and DYNAMIXEL-Q actuators; some hardware resources remain announced rather than released.
| Height | 135.5 cm |
|---|---|
| Weight | 35 kg |
| Degrees of freedom | 23: 5 per arm, 6 per leg and 1 waist |
| Actuators | 12 × QC060-200-R020-RE; 11 × QC080-240-R020-RE |
| Development resources | ROS 2, simulation and learning workflows |
Product information checked on 2026-10-28. Manufacturer figures may use different configurations and test conditions.
No verified partner offer is currently available for this model.
Manufacturer video · ROBOTIS OpenSourceTeam
Robots with a shared category or task. Compare their documented capabilities and deployment requirements.
Industrial humanoid development
Industrial robotics development